Robotics · 2025
Autonomous battle bot
An ESP32-based battle bot with autonomous operation and Wi-Fi control.
Problem
The goal was to construct a robot that could complete both autonomous and manually controlled tasks. The main engineering challenge was integrating the mechanical structure, motor control, sensing, embedded electronics, and software into a compact and reliable robotic system.
Design & Fabrication
My robot was designed with a two-layer platform, with the lower layer housing the primary electronics, motor driver and battery, while the upper layer supported the sensing hardware. My teammate and I opted for a two-wheel forward-drive configuration to ensure stable and predictable motion.
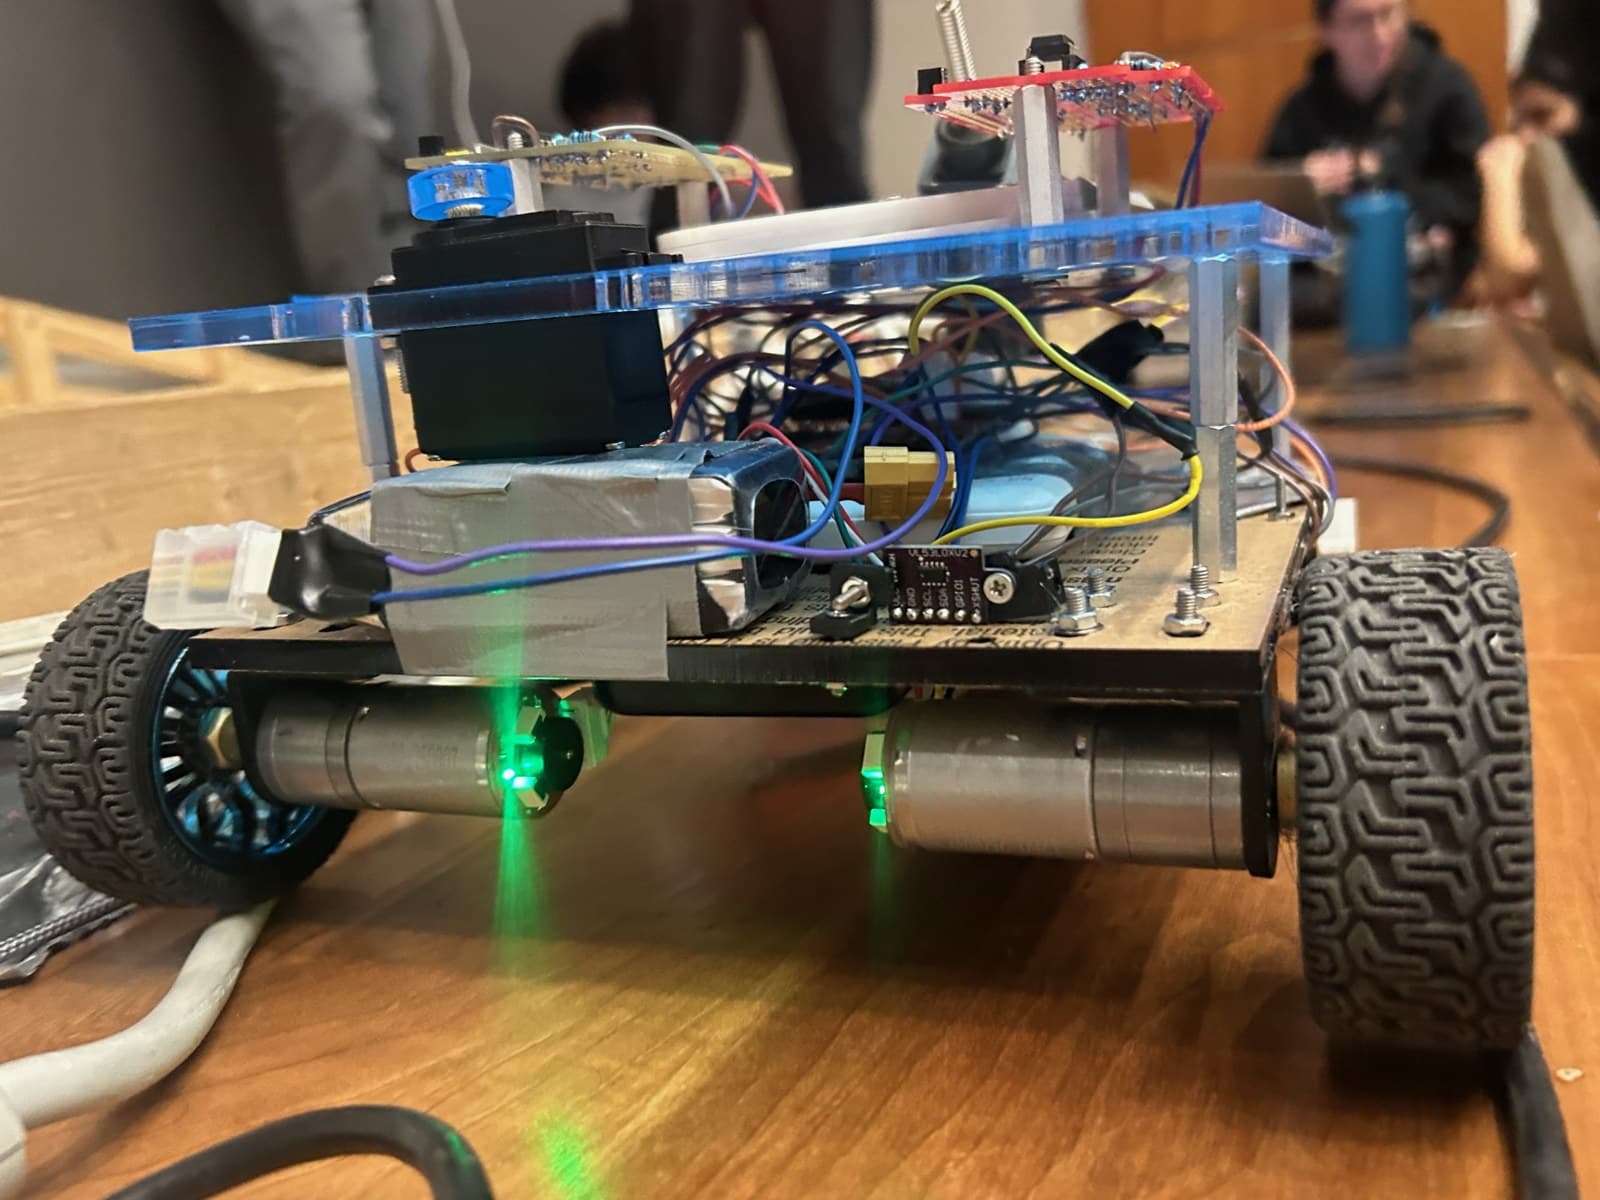
The robot was controlled using ESP32 microcontrollers interfacing with the motors, quadrature encoders, TOF sensors, and motor driver. To achieve consistent motion, the robot used closed-loop PID motor control based on encoder feedback. For autonomous navigation, two TOF sensors measured the robot’s distance from the surrounding walls. A PD controller used the measured distances as feedback to adjust the robot’s motion and maintain a desired offset.
We also implemented a web-based interface to allow for remote robot control, allowing the operator to adjust speed, enable autonomous behaviour, and stop the robot.
A significant part of the project involved iterative testing and troubleshooting across the mechanical, electrical, and software systems. Testing focused on improving electrical reliability, sensor initialization, motor control, and PID turning.
Impact
The project provided hands-on experience developing a robotic system from the component level through full-system integration. It strengthened my experience with embedded controls, closed-loop motor control, sensor integration, rapid prototyping, debugging, and iterative hardware/software development while demonstrating the importance of integrating mechanical, electrical, and software systems into a reliable mechatronics platform.
Tools/Methods
ESP32, Arduino/C++, PID control, WiFi, CAD, 3D printing, laser cutting, motor encoders, time-of-flight (TOF) sensors, soldering, electrical integration